Stating the Divergence Theorem
The divergence theorem follows the general pattern of the other theorems we’ve studied. If we think of divergence as a derivative of sorts, then the divergence theorem relates a triple integral of derivative div [latex]\mathbf{F}[/latex] over a solid to a flux integral of [latex]\mathbf{F}[/latex] over the boundary of the solid.
More specifically, the divergence theorem relates a flux integral of vector field [latex]\mathbf{F}[/latex] over a closed surface [latex]S[/latex] to a triple integral of the divergence of [latex]\mathbf{F}[/latex] over the solid enclosed by [latex]S[/latex].
the divergence theorem
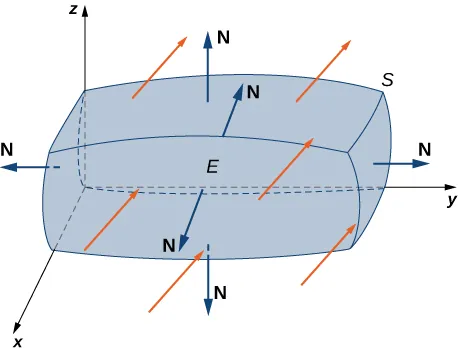
Let [latex]S[/latex] be a piecewise, smooth closed surface that encloses solid [latex]E[/latex] in space. Assume that [latex]S[/latex] is oriented outward, and let [latex]{\bf{F}}[/latex] be a vector field with continuous partial derivatives on an open region containing [latex]E[/latex] (Figure 1). Then:
[latex]\displaystyle\iiint_e\text{div }{\bf{F}}dV=\displaystyle\int_C{\bf{F}}\cdot d{\bf{S}}[/latex].
The proof of the divergence theorem is beyond the scope of this text. However, we look at an informal proof that gives a general feel for why the theorem is true, but does not prove the theorem with full rigor. This explanation follows the informal explanation given for why Stokes’ theorem is true.
Proof
Let [latex]B[/latex] be a small box with sides parallel to the coordinate planes inside [latex]E[/latex] (Figure 2). Let the center of [latex]B[/latex] have coordinates [latex](x, y, z)[/latex] and suppose the edge lengths are [latex]\Delta x[/latex], [latex]\Delta y[/latex], and [latex]\Delta z[/latex] (Figure 2(b)). The normal vector out of the top of the box is [latex]{\bf{k}}[/latex] and the normal vector out of the bottom of the box is [latex]-{\bf{k}}[/latex]. The dot product of [latex]{\bf{F}}=\langle P,Q,R\rangle[/latex] with [latex]{\bf{k}}[/latex] is [latex]R[/latex] and the dot product with [latex]-{\bf{k}}[/latex] is [latex]-R[/latex]. The area of the top of the box (and the bottom of the box) [latex]\Delta S[/latex] is [latex]\Delta x\Delta y[/latex].
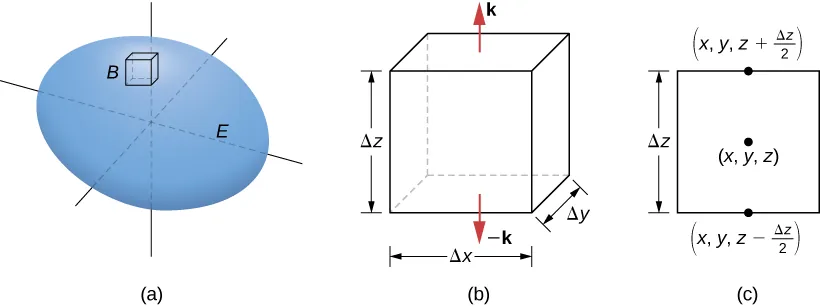
The flux out of the top of the box can be approximated by [latex]R\left(x,y,z+\frac{\Delta z}{2}\right)\Delta x\Delta y[/latex] (Figure 2(c)) and the flux out of the bottom of the box is [latex]-R\left(x,y,z-\frac{\Delta z}{2}\right)\Delta x\Delta y[/latex]. If we denote the difference between these values as [latex]\Delta R[/latex], then the net flux in the vertical direction can be approximated by [latex]\Delta R\Delta x\Delta y[/latex]. However,
[latex]\large{\Delta R\Delta x\Delta y=\left(\frac{\Delta R}{\Delta z}\right)\Delta x\Delta y\Delta z\approx\left(\frac{\partial R}{\partial z}\right)\Delta V}[/latex].
Therefore, the net flux in the vertical direction can be approximated by [latex]\left(\frac{\partial R}{\partial z}\right)\Delta V[/latex]. Similarly, the net flux in the [latex]x[/latex]-direction can be approximated by [latex]\left(\frac{\partial P}{\partial x}\right)\Delta V[/latex] and the net flux in the [latex]y[/latex]-direction can be approximated by [latex]\left(\frac{\partial Q}{\partial y}\right)\Delta V[/latex]. Adding the fluxes in all three directions gives an approximation of the total flux out of the box:
Total flux [latex]\approx\left(\frac{\partial P}{\partial x}+\frac{\partial Q}{\partial y}+\frac{\partial R}{\partial z}\right)\Delta V=\text{div }{\bf{F}}\Delta V[/latex].
This approximation becomes arbitrarily close to the value of the total flux as the volume of the box shrinks to zero.
The sum of [latex]\text{div }{\bf{F}}\Delta V[/latex] over all the small boxes approximating [latex]E[/latex] is approximately [latex]\displaystyle\iiint_E\text{div }{\bf{F}}dV[/latex]. On the other hand, the sum of [latex]\text{div }{\bf{F}}\Delta V[/latex] over all the small boxes approximating [latex]E[/latex] is the sum of the fluxes over all these boxes. Just as in the informal proof of Stokes’ theorem, adding these fluxes over all the boxes results in the cancelation of a lot of the terms. If an approximating box shares a face with another approximating box, then the flux over one face is the negative of the flux over the shared face of the adjacent box. These two integrals cancel out. When adding up all the fluxes, the only flux integrals that survive are the integrals over the faces approximating the boundary of [latex]E[/latex]. As the volumes of the approximating boxes shrink to zero, this approximation becomes arbitrarily close to the flux over [latex]S[/latex].
[latex]_\blacksquare[/latex]
Physical Interpretation of Divergence
Recall that the divergence of continuous field [latex]\mathbf{F}[/latex] at point [latex]P[/latex] is a measure of the “outflowing-ness” of the field at [latex]P[/latex]. If [latex]\mathbf{F}[/latex] represents the velocity field of a fluid, then the divergence can be thought of as the rate per unit volume of the fluid flowing out less the rate per unit volume flowing in. The divergence theorem confirms this interpretation.
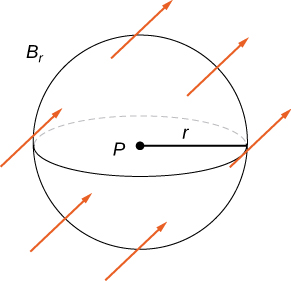
To see this, let [latex]P[/latex] be a point and let [latex]B_r[/latex] be a ball of small radius [latex]r[/latex] centered at [latex]P[/latex] (Figure 4). Let [latex]S_r[/latex] be the boundary sphere of [latex]B_r[/latex].
Since the radius is small and [latex]{\bf{F}}[/latex] is continuous, [latex]\text{div }{\bf{F}}(Q)\approx\text{div }{\bf{F}}(P)[/latex] for all other points [latex]Q[/latex] in the ball. Therefore, the flux across [latex]S_r[/latex] can be approximated using the divergence theorem:
[latex]\displaystyle\iint_{S_r}{\bf{F}}\cdot dS=\displaystyle\iiint_{B_r}\text{div }{\bf{F}}dV\approx\displaystyle\iiint_{B_r}\text{div }{\bf{F}}(P)dV[/latex].
Since [latex]\text{div }{\bf{F}}(P)[/latex] is a constant,
[latex]\displaystyle\iiint_{B_r}\text{div }{\bf{F}}(P)dV=\text{div }{\bf{F}}(P)V(B_r)[/latex].
Therefore, flux [latex]\displaystyle\iint_{S_r}{\bf{F}}\cdot d{\bf{S}}[/latex] can be approximated by [latex]\text{div }{\bf{F}}(P)V(B_r)[/latex]. This approximation gets better as the radius shrinks to zero, and therefore:
[latex]\text{div }{\bf{F}}(P)=\displaystyle\lim_{r\to0}\frac{1}{V(B_r)}\displaystyle\iint_{S_r}{\bf{F}}\cdot d{\bf{S}}[/latex].
This equation says that the divergence at [latex]P[/latex] is the net rate of outward flux of the fluid per unit volume.