- Calculate the cross product of two vectors and understand what it tells us
- Find a vector orthogonal to two given vectors
- Determine areas and volumes by using the cross product
- Calculate the torque of a given force and position vector
The Cross Product
Imagine a mechanic turning a wrench to tighten a bolt. The mechanic applies force at the end of the wrench, creating rotation (torque) that tightens the bolt.
We can represent both the applied force and the radius from bolt to wrench end as vectors. The resulting torque is also a vector, but it points along the axis of rotation—perpendicular to both the force vector and radius vector. How do we find a vector perpendicular to two given vectors? The cross product provides the answer.
The dot product multiplies two vectors to get a scalar. The cross product multiplies two vectors to get a third vector that’s orthogonal to both original vectors. Let’s see how this works.
Given vectors [latex]\mathbf{u} = \langle u_1, u_2, u_3 \rangle[/latex] and [latex]\mathbf{v} = \langle v_1, v_2, v_3 \rangle[/latex], we want to find vector [latex]\mathbf{w} = \langle w_1, w_2, w_3 \rangle[/latex] such that:
- [latex]\mathbf{u} \cdot \mathbf{w} = 0[/latex] (orthogonal to [latex]\mathbf{u}[/latex])
- [latex]\mathbf{v} \cdot \mathbf{w} = 0[/latex] (orthogonal to [latex]\mathbf{v}[/latex])
This gives us the system of equations:
[latex]\begin{aligned} u_1w_1 + u_2w_2 + u_3w_3 &= 0 \\ v_1w_1 + v_2w_2 + v_3w_3 &= 0.\\ \end{aligned}[/latex]
Through algebraic manipulation (multiplying and eliminating variables), we find:
[latex]w_1 = u_2v_3 - u_3v_2[/latex]
[latex]w_2 = -(u_1v_3 - u_3v_1) = u_3v_1 - u_1v_3[/latex]
[latex]w_3 = u_1v_2 - u_2v_1[/latex]
That is, vector
is orthogonal to both [latex]\textbf u[/latex] and [latex]\textbf v[/latex]
cross product
For vectors [latex]\mathbf{u} = \langle u_1, u_2, u_3 \rangle[/latex] and [latex]\mathbf{v} = \langle v_1, v_2, v_3 \rangle[/latex]:
Component Form:
[latex]\mathbf{u} \times \mathbf{v} = \langle u_2v_3 - u_3v_2, u_3v_1 - u_1v_3, u_1v_2 - u_2v_1 \rangle[/latex]
Standard Unit Vector Form:
[latex]\mathbf{u} \times \mathbf{v} = (u_2v_3 - u_3v_2)\mathbf{i} - (u_1v_3 - u_3v_1)\mathbf{j} + (u_1v_2 - u_2v_1)\mathbf{k}[/latex]
Orthogonality Check
Let’s verify that [latex]\mathbf{u} \times \mathbf{v}[/latex] is indeed orthogonal to [latex]\mathbf{u}[/latex] by computing their dot product:
The terms cancel out perfectly! Similarly, we can show that [latex]\mathbf{v} \cdot (\mathbf{u} \times \mathbf{v}) = 0[/latex].
Cross Product vs. Dot Product:
- Dot product: Two vectors → scalar
- Cross product: Two vectors → vector (orthogonal to both inputs)
Direction: The Right-Hand Rule
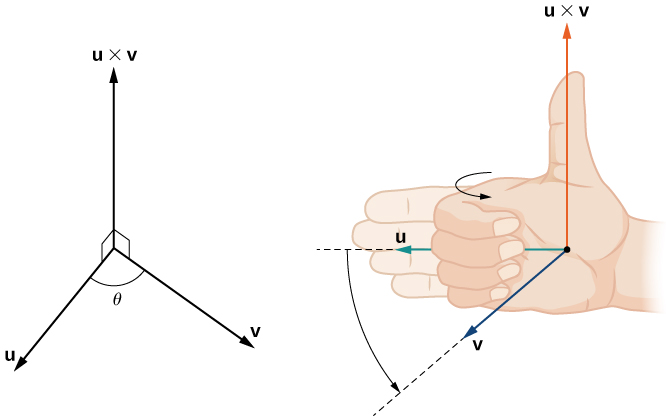
The cross product formula tells us the components of [latex]\mathbf{u} \times \mathbf{v}[/latex], but how do we determine its direction? The right-hand rule provides the answer.
Right-Hand Rule Steps:
- Point your right hand fingers in the direction of the first vector [latex]\mathbf{u}[/latex]
- Curl your fingers toward the second vector [latex]\mathbf{v}[/latex]
- Your thumb points in the direction of [latex]\mathbf{u} \times \mathbf{v}[/latex]

Cross Products of Standard Unit Vectors
Understanding how [latex]\mathbf{i}[/latex], [latex]\mathbf{j}[/latex], and [latex]\mathbf{k}[/latex] interact under cross multiplication simplifies many calculations.
When crossing a unit vector with itself:
[latex]\mathbf{i} \times \mathbf{i} = \mathbf{j} \times \mathbf{j} = \mathbf{k} \times \mathbf{k} = \mathbf{0}[/latex]
This makes sense—a vector crossed with itself has no meaningful perpendicular direction, so the result is the zero vector.
When crossing different unit vectors:
Since the cross product of two different unit vectors must be perpendicular to both, it must be parallel to the third unit vector. The right-hand rule determines whether it’s positive or negative:
unit vector cross products
Positive Results (right-hand rule gives positive direction):
- [latex]\mathbf{i} \times \mathbf{j} = \mathbf{k}[/latex]
- [latex]\mathbf{j} \times \mathbf{k} = \mathbf{i}[/latex]
- [latex]\mathbf{k} \times \mathbf{i} = \mathbf{j}[/latex]
Negative Results (opposite order gives negative direction):
- [latex]\mathbf{j} \times \mathbf{i} = -\mathbf{k}[/latex]
- [latex]\mathbf{k} \times \mathbf{j} = -\mathbf{i}[/latex]
- [latex]\mathbf{i} \times \mathbf{k} = -\mathbf{j}[/latex]
Properties of the Cross Product
The dot product and cross product are both forms of vector multiplication, but they have very different properties and applications. The dot product is called the scalar product because it produces a scalar, while the cross product is called the vector product because it produces a vector.
properties of the cross product:
Let [latex]\mathbf{u}[/latex], [latex]\mathbf{v}[/latex], and [latex]\mathbf{w}[/latex] be vectors, and let [latex]c[/latex] be a scalar.
- Anticommutative: [latex]\mathbf{u} \times \mathbf{v} = -(\mathbf{v} \times \mathbf{u})[/latex]
- Distributive: [latex]\mathbf{u} \times (\mathbf{v} + \mathbf{w}) = \mathbf{u} \times \mathbf{v} + \mathbf{u} \times \mathbf{w}[/latex]
- Scalar multiplication: [latex]c(\mathbf{u} \times \mathbf{v}) = (c\mathbf{u}) \times \mathbf{v} = \mathbf{u} \times (c\mathbf{v})[/latex]
- Zero vector: [latex]\mathbf{u} \times \mathbf{0} = \mathbf{0} \times \mathbf{u} = \mathbf{0}[/latex]
- Self cross product: [latex]\mathbf{v} \times \mathbf{v} = \mathbf{0}[/latex]
- Scalar triple product: [latex]\mathbf{u} \times (\mathbf{v} \times \mathbf{w}) \neq (\mathbf{u} \times \mathbf{v}) \times \mathbf{w}[/latex] (in general)
Proof
For property i., we want to show [latex]\mathbf{u \times v} = -( \mathbf{v \times u})[/latex]. We have
Unlike most operations we’ve seen, the cross product is not commutative. This makes sense if we think about the right-hand rule.
For property iv., this follows directly from the definition of the cross product. We have
Then, by property i., [latex]\mathbf{0} \times \mathbf{u} = \mathbf{0}[/latex] as well. Remember that the dot product of a vector and the zero vector is the scalar [latex]0[/latex], whereas the cross product of a vector with the zero vector is the vector [latex]\textbf 0[/latex].
Property vi. looks like the associative property, but note the change in operations:
[latex]_\blacksquare[/latex]
Magnitude of the Cross Product
We’ve focused on the direction of [latex]\mathbf{u} \times \mathbf{v}[/latex], but what about its magnitude? It turns out there is a simple expression for the magnitude of [latex]\mathbf{u} \times \mathbf{v}[/latex] involving the magnitudes of [latex]\mathbf u[/latex] and [latex]\mathbf v[/latex], and the sine of the angle between them.
magnitude of the cross product
For vectors [latex]\mathbf{u}[/latex] and [latex]\mathbf{v}[/latex] with angle [latex]\theta[/latex] between them:
[latex]||\mathbf{u} \times \mathbf{v}|| = ||\mathbf{u}|| \cdot ||\mathbf{v}|| \cdot \sin \theta[/latex]
Proof
Let [latex]\mathbf{u} = \langle u_1,u_2, u_3\rangle[/latex] and [latex]\mathbf{v} = \langle v_1,v_2, v_3\rangle[/latex] be vectors, and let [latex]\theta[/latex] denote the angle between them. Then
Taking square roots and noting that [latex]\sqrt{\sin^2{\theta}} = \sin{\theta}[/latex] for [latex]0\geq \theta \geq 180[/latex], we have the desired result:
The cross product only works in three dimensions. In 2D, there’s no direction simultaneously perpendicular to two nonparallel vectors—you’d need to point “out of the plane,” which requires a third dimension. This geometric requirement explains why cross products are fundamental in 3D applications like torque, rotation, and magnetic fields, but don’t exist in 2D vector algebra.