You’ve seen that the derivative [latex]{\bf{r}}'(t)[/latex] of a vector-valued function is a tangent vector to the curve, and the unit tangent vector [latex]{\bf{T}}(t)[/latex] can be calculated by dividing [latex]{\bf{r}}'(t)[/latex] by its magnitude. When studying motion in three dimensions, two other vectors are useful for describing the motion of a particle along a path in space: the principal unit vector and the binomial vector.
principal unit normal vector and binormal vector
Let [latex]C[/latex] be a three-dimensional smooth curve represented by [latex]{\bf{r}}[/latex] over an open interval [latex]I[/latex].
[latex]\\[/latex]
Principal unit normal vector: If [latex]{\bf{T}}'(t)\neq 0[/latex], then the principal unit normal vector at [latex]t[/latex] is:
where [latex]{\bf{T}}(t)[/latex] is the unit tangent vector.
By definition, the binormal vector is orthogonal to both the unit tangent vector and the normal vector. Additionally, [latex]{\bf{B}}(t)[/latex] is always a unit vector.
We can verify that [latex]{\bf{B}}(t)[/latex] is a unit vector using the formula for the magnitude of a cross product:
where [latex]\theta[/latex] is the angle between [latex]{\bf{T}}(t)[/latex] and [latex]{\bf{N}}(t)[/latex]. Since [latex]{\bf{N}}(t)[/latex] is the derivative of a unit vector, we know from earlier properties that [latex]{\bf{T}}(t)[/latex] and [latex]{\bf{N}}(t)[/latex] are orthogonal to each other, so [latex]\theta=\frac{\pi}{2}[/latex]. Both are unit vectors with magnitude [latex]1[/latex]. Therefore:
This confirms that [latex]{\bf{B}}(t)[/latex] is a unit vector.
The principal unit normal vector can be challenging to calculate because the unit tangent vector involves a quotient, often with a square root in the denominator. In three dimensions, finding the cross product of the unit tangent vector and the unit normal vector can be even more cumbersome. Fortunately, alternative formulas exist for finding these vectors, which are presented presented in section on Motion in Space
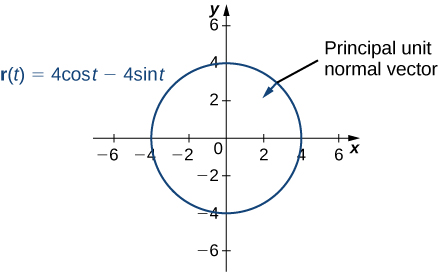
For each of the following vector-valued functions, find the principal unit normal vector. Then, if possible, find the binormal vector.
Furthermore, the principal unit normal vector points toward the center of the circle from every point on the circle. Since [latex]{\bf{r}}(t)[/latex] defines a curve in two dimensions, we cannot calculate the binormal vector
Figure 2.
This function looks like this:
Figure 3.
To find the principal unit normal vector, we first find the unit tangent vector [latex]{\bf{T}}(t)[/latex]:
Last, since [latex]{\bf{r}}(t)[/latex] represents a three-dimensional curve, we can calculate the binormal vector using the first equation from the above definition:
For any smooth curve in three dimensions defined by a vector-valued function, we now have formulas for three important vectors: the unit tangent vector [latex]{\bf{T}}[/latex], the unit normal vector [latex]{\bf{N}}[/latex], and the binormal vector [latex]{\bf{B}}[/latex].
The unit normal vector and the binormal vector form a plane perpendicular to the curve at any point, called the normal plane. These three vectors together form a frame of reference in three-dimensional space called the Frenet frame of reference (also called the TNB frame), shown in Figure 1. The plane determined by the vectors [latex]{\bf{T}}[/latex] and [latex]{\bf{N}}[/latex] forms the osculating plane of [latex]C[/latex] at any point [latex]P[/latex] on the curve.
Figure 4. This figure depicts a Frenet frame of reference. At every point [latex]P[/latex] on a three-dimensional curve, the unit tangent, unit normal, and binormal vectors form a three-dimensional frame of reference.
The Osculating Circle
Suppose we form a circle in the osculating plane of [latex]C[/latex] at point [latex]P[/latex] on the curve. Assume the circle has the same curvature as the curve does at point [latex]P[/latex] and has radius [latex]r[/latex]. Then the curvature of the circle is [latex]\frac{1}{r}[/latex]. We call [latex]r[/latex] the radius of curvature of the curve—it equals the reciprocal of the curvature.
If this circle lies on the concave side of the curve and is tangent to the curve at point [latex]P[/latex], then this circle is called the osculating circle of [latex]C[/latex] at [latex]P[/latex], as shown in Figure 2.
Figure 5. In this osculating circle, the circle is tangent to curve [latex]C[/latex] at point [latex]P[/latex] and shares the same curvature.
To find the equation of an osculating circle in two dimensions, you need only the center and radius of the circle. The radius is the reciprocal of the curvature at that point.
Find the equation of the osculating circle of the helix defined by the function [latex]y=x^{3}-3x+1[/latex] at [latex]x=1[/latex].
Figure 9 shows the graph of [latex]y=x^{3}-3x+1[/latex].
Figure 6. We want to find the osculating circle of this graph at the point where [latex]t=1[/latex].
First, let’s calculate the curvature at [latex]x=1[/latex]:
This gives [latex]\kappa=6[/latex]. Therefore, the radius of the osculating circle is given by [latex]R=\frac{1}{\kappa}=\frac{1}{6}[/latex]. Next, we then calculate the coordinates of the center of the circle. When [latex]x=1[/latex], the slope of the tangent line is zero. Therefore, the center of the osculating circle is directly above the point on the graph with coordinates [latex](1,\ -1)[/latex]. The center is located at [latex](1,\ -\frac{5}{6})[/latex]. The formula for a circle with radius [latex]r[/latex] and center [latex](h,\ k)[/latex] is given by [latex](x-h)^{2}+(y-k)^{2}=r^{2}[/latex]. Therefore, the equation of the osculating circle is [latex](x-1)^{2}+(y+\frac{5}{6})^{2}=\frac{1}{36}[/latex]. The graph and its osculating circle appears in the following graph.
Figure 8. The osculating circle has radius [latex]R=\frac{1}{6}[/latex]